Close Menu
Techy101 –

    Subscribe to Updates

    Get the latest creative news from FooBar about art, design and business.

    What's Hot

    Apple’s new touchscreen MacBook Pro isn’t exactly repair-friendly. I’d be extra careful when carrying it.

    November 11, 2026

    Final Fantasy 14 players are gathering in virtual vigils to honour the passing of the game’s most prestigious bass player

    November 11, 2026

    Edelbyte Raises $70M to Build Data Infrastructure for AI Agents – Unite.AI

    November 11, 2026
    Facebook X (Twitter) Instagram
    Trending
    • Apple’s new touchscreen MacBook Pro isn’t exactly repair-friendly. I’d be extra careful when carrying it.
    • Final Fantasy 14 players are gathering in virtual vigils to honour the passing of the game’s most prestigious bass player
    • Edelbyte Raises $70M to Build Data Infrastructure for AI Agents – Unite.AI
    • Your old Android phone can run a real Linux desktop, and Termux is all it takes to get started
    • Sharing Lessons Across AI Sessions
    • Pixel Journal inches closes towards Google Recorder integration
    • What Happens When Two Games Have The Same Title? Indie Publisher Reveals Heartwarming Answer
    • Monster Hunter Wilds’ upcoming Ascendance expansion may be getting a beta, some curious Steam backend updates suggest
    Facebook X (Twitter) Instagram Pinterest YouTube LinkedIn TikTok
    Techy101 –Techy101 –
    • Home
    • Laptops
    • Mobiles
    • Gaming
    • Gadgets
    • Apps
    • AI
    • How To
    • Reviews
    Techy101 –
    Home»AI»NTT’s Physics-Based World Model Screens Robot Actions Before Execution – Unite.AI
    AI

    NTT’s Physics-Based World Model Screens Robot Actions Before Execution – Unite.AI

    By RepublisherNovember 11, 2026No Comments3 Mins Read
    Share Facebook Twitter Pinterest LinkedIn Tumblr Reddit Telegram Email
    NTT’s Physics-Based World Model Screens Robot Actions Before Execution – Unite.AI
    Share
    Facebook Twitter LinkedIn Pinterest Email


    On November 11, 2026, NTT, Inc. announced a physics-based world model that evaluates candidate robot actions before execution to reduce failures such as dropped objects and collapsing loads, saying the technology raised task success in a small-robot shelf-loading test from 73.1% to 92.3%.

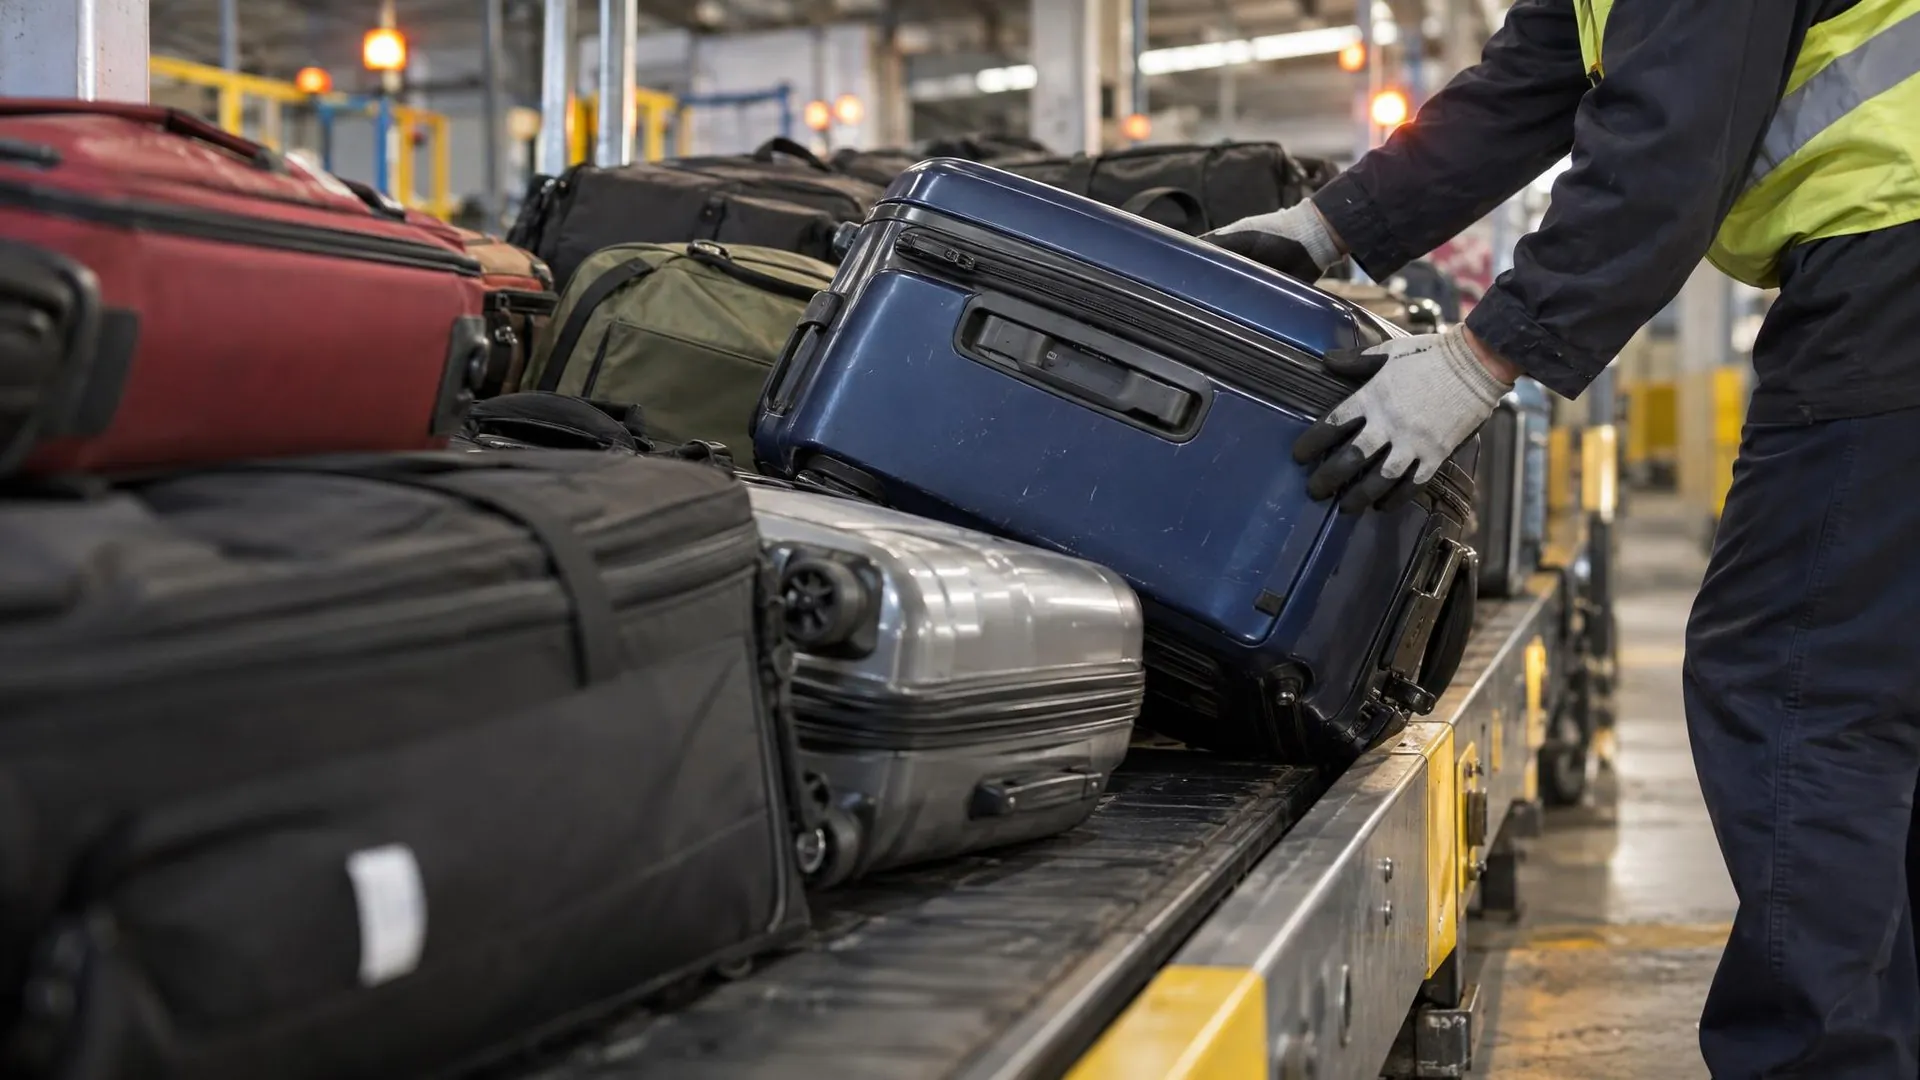
    The first envisioned application is automated loading and unloading of airport baggage. Variation in luggage shape, weight, and arrangement makes it difficult for conventional robot control alone to determine in advance whether an action will collapse a load or drop an item, and collecting training data for every possible item is impractical. NTT plans field trials with Mujin, Inc. for baggage handling.

    How the Model Evaluates Candidate Actions

    The technology works with existing robot control software, adding prediction and evaluation before movement. Candidates can come from a vision-language-action model, which converts camera video and language instructions into robot actions, or from a motion planner, which calculates the controls needed to achieve a task objective. For each option, it generates predicted video and evaluates collisions, drops, and load collapse, producing a score that lets the control program choose an action assessed as likely to succeed.

    NTT says conventional world models do not explicitly represent objects’ physical quantities, which can produce disappearing or implausibly deforming objects in generated video and inaccurate collision predictions. Their dependence on large training datasets also makes failures more likely in situations absent from that data.

    NTT’s physics control adapter estimates properties including each object’s position, orientation, velocity, and mass from video, applies physical laws to calculate subsequent motion, and supplies those calculations to the video generation model. NTT says this explicit representation can address situations and motions absent from training data. The model also outputs the physical quantities behind a prediction, making the basis for the generated result easier to understand.

    Benchmark Results and Expansion Plans

    NTT also evaluated future-video accuracy on the public OBJ3D benchmark, which contains video frames of synthetic objects colliding. NTT reports that its model outperformed conventional methods on Learned Perceptual Image Patch Similarity (LPIPS), a metric comparing predicted video with ground truth in a manner aligned with human perception; lower values indicate greater similarity.

    Beyond baggage and parcel handling, NTT plans to pursue logistics, warehousing, manufacturing, construction, and retail applications and will consider working with robot service providers and logistics and warehousing companies. Reduced labor requirements and improved productivity are objectives for that expansion, not outcomes established by the reported test.

    The technology is scheduled for exhibition at NTT R&D Forum 2026, an invitation-only event running November 18–20, 2026, and November 24–25, 2026. A November 25, 2026, seminar on AI robotics and the physics-informed world model lists Mujin Japan CEO Isamu Arase and NTT executive research engineer Jun Shimamura as speakers.

    NTT’s announced results cover a small-robot task and synthetic collision videos. The planned Mujin trials will test whether the reported shelf-loading improvement transfers to airport baggage handling, where pre-execution screening must address the physical variation that motivated the model’s development.


    Source link

    actions Execution model NTTs PhysicsBased Robot screens Unite.AI World
    Share. Facebook Twitter Pinterest LinkedIn Tumblr Email
    Previous ArticleEnd of an era: Apple Support Community forums to permanently close
    Next Article Monster Hunter Wilds’ upcoming Ascendance expansion may be getting a beta, some curious Steam backend updates suggest
    Republisher
    • Website

    Related Posts

    AI

    Edelbyte Raises $70M to Build Data Infrastructure for AI Agents – Unite.AI

    November 11, 2026
    AI

    Sharing Lessons Across AI Sessions

    November 11, 2026
    AI

    TIER IV Details Five Open-Source Models for Autonomous Driving – Unite.AI

    November 11, 2026
    Add A Comment
    Leave A Reply Cancel Reply

    Top Posts

    Apple’s new touchscreen MacBook Pro isn’t exactly repair-friendly. I’d be extra careful when carrying it.

    November 11, 2026

    AMD is apparently gearing up to raise GPU prices right after Nvidia’s steep hike

    August 1, 2026

    LanceDB Vector Database Guide: Features anndPython Demo

    August 1, 2026
    Stay In Touch
    • Facebook
    • YouTube
    • TikTok
    • WhatsApp
    • Twitter
    • Instagram
    Latest Reviews

    Subscribe to Updates

    Get the latest tech news from FooBar about tech, design and biz.

    Latest Post

    Apple’s new touchscreen MacBook Pro isn’t exactly repair-friendly. I’d be extra careful when carrying it.

    November 11, 2026

    AMD is apparently gearing up to raise GPU prices right after Nvidia’s steep hike

    August 1, 2026

    LanceDB Vector Database Guide: Features anndPython Demo

    August 1, 2026
    Recent Posts
    • Apple’s new touchscreen MacBook Pro isn’t exactly repair-friendly. I’d be extra careful when carrying it.
    • Final Fantasy 14 players are gathering in virtual vigils to honour the passing of the game’s most prestigious bass player
    • Edelbyte Raises $70M to Build Data Infrastructure for AI Agents – Unite.AI
    • Your old Android phone can run a real Linux desktop, and Termux is all it takes to get started
    • Sharing Lessons Across AI Sessions

    Subscribe to Updates

    Get the latest creative news from FooBar about art, design and business.

    Facebook X (Twitter) Instagram Pinterest YouTube LinkedIn TikTok
    • About Us
    • Contact Us
    • Privacy Policy
    • Terms & Conditions
    • Disclaimer
    © 2026 techy101. Designed by Pro.

    Type above and press Enter to search. Press Esc to cancel.